If you’re a manufacturer relying on pick and place robots for high-volume, precision-driven tasks—think electronics assembly, food packaging, or small component sorting—you already know these machines are the backbone of your efficiency. But here’s a truth most operators miss: even the most reliable pick and place robot won’t perform at its peak if its software is outdated. For years, I’ve worked directly with factories as a pick and place robot supplier, and I’ve seen too many teams wait until their robot crashes mid-production, slows down, or misplaces components before patching software. This is a costly mistake: unpatched software can lead to 15%+ production delays, unplanned downtime costing thousands per hour, and even safety risks if motion controls are outdated. Pick and Place Robot
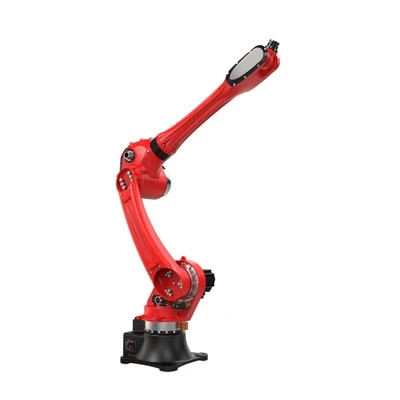
Today, I’m walking you through a step-by-step, field-tested process to update your pick and place robot’s software the right way. No rushed downloads, no messy reconfigurations, no lost production time. This is the same method we use for every client installation, and it’s tailored specifically to the unique needs of pick and place robots—machines that move fast, handle delicate parts, and operate in tight workspaces.
First, let’s start with why this matters more than you think. A pick and place robot’s software isn’t just a “control panel” for moving parts. It’s the brain that coordinates every joint’s speed, grip force, camera alignment, and collision avoidance. Outdated software can mean:
- Inconsistent grip pressure: For fragile parts like smartphone screens or microchips, too much force cracks the component; too little causes it to slip. Our team has had clients come to us after a $50,000 batch of sensors were ruined because their robot’s grip algorithm was 3 years old, and it couldn’t adapt to minor material thickness changes.
- Slow cycle times: New software includes optimized motion planning that cuts 100–200 milliseconds off each pick-and-place cycle. Multiply that over 10,000 cycles a day, and you’re gaining 10–20 minutes of extra production time daily—no hardware upgrade needed.
- Compliance gaps: If you’re in food or medical device manufacturing, regulatory bodies require updated software to ensure traceability and worker safety. Outdated versions may no longer meet current ISO or OSHA standards, putting your facility at risk of fines.
Now, let’s get to the process. We break this into 5 core steps, designed to be safe, reliable, and non-disruptive to your production schedule.
Step 1: Pre-Update Assessment (The Most Important Step, Skipped by Most Teams)
Before you touch a single software file, you need to map out exactly what your robot’s current setup is—and what it needs. Too often, clients start updating without checking if their hardware is compatible. For example, a 2018 pick and place robot with a legacy camera module won’t run the latest software that requires a 2021 vision sensor. This step avoids that.
First, pull your robot’s current configuration log. Most modern pick and place robots store this locally, or our team can send it to you on request. This log has details like: robot model number, firmware version, vision system type, end-of-arm tool (EOAT) specs, and motion limit settings.
Next, align this with the software update you want. As a supplier, we only release updates that are validated for your specific robot model—no generic downloads. You should never install a software version for a different pick and place line, even if it’s from the same manufacturer. We also recommend checking for compatibility with your production line’s other tools: does the new software integrate with your conveyor system, barcode scanners, or quality check cameras? A bad integration can cause more errors than no update at all.
Finally, schedule the update during a planned downtime window. We always tell clients to pick a time when production is paused for at least 2–3 hours—never during a high-volume run. This gives you room to troubleshoot if something goes wrong, without delaying your order to customers.
Step 2: Backup All Critical Data (Don’t Lose Your Custom Settings)
Your pick and place robot’s most valuable data isn’t the software—it’s the custom settings you’ve spent weeks perfecting. These include: EOAT grip force calibrations, pick positions for specific components, motion speed limits to avoid collisions with workcell walls, and custom cycle priorities (e.g., handling high-value parts first). Backing this up is non-negotiable.
Here’s how to do it right: first, export a full system backup from your robot’s programming interface. Most models use a USB drive for this—plug in a formatted, empty drive, select “Backup System Data,” and wait 5–10 minutes. Label this drive clearly with your robot ID and the current date.
But don’t stop there. If your robot has a vision system, export the component mapping files too. These are the files that tell the camera to recognize a 0201 surface-mount resistor vs. a capacitor. Losing these would mean re-calibrating the entire vision system, which can take a full production day. We recommend storing this backup in two places: the local USB drive, and a secure cloud folder (we offer cloud backup for our clients, but you can use your company’s secure storage too).
Pro tip from our field team: Test your backup by restoring it to a spare robot (if you have one) or a virtual simulator. Last year, a client skipped this step and lost their custom calibration after an update—they spent 8 hours resetting the robot, when a 10-minute restore test would have caught the backup file was corrupted.
Step 3: Install the Software Update Safely
Now it’s time to run the update—but never do this on the factory floor without basic prep. First, disconnect non-critical peripherals: if your robot is connected to a remote status monitor or a spare barcode scanner, unplug those to avoid data conflicts. Ensure the robot’s main power is stable—no brownouts during the update can brick the firmware. We recommend using an uninterruptible power supply (UPS) for the robot during this process, especially for high-throughput models.
Next, load the update file. For most pick and place robots, this is done via USB or a secure network connection (we prefer USB for on-site updates to avoid network-related errors). When you start the installer, read every prompt carefully. Some updates will ask if you want to preserve custom settings—always select “Yes.” If the option is hidden, our team advises a “minimal install” that keeps your existing configuration, rather than a full reset.
During installation, don’t interrupt the process. It can take 15–45 minutes depending on the robot model. You’ll see a progress bar—even if it seems stuck at 50% for a few minutes, wait it out. Last quarter, a factory team manually canceled an update because they thought it failed, and they ended up re-installing from scratch, losing 2 hours of downtime.
Once the update is complete, the robot will automatically restart. Don’t power it on manually—wait for the system to boot fully, which can take an extra 5 minutes.
Step 4: Calibrate and Test (Catch Errors Before Production)
This is where many teams cut corners, and it’s the reason 30% of post-update issues we see are avoidable. Software updates change how the robot’s brain communicates with its hardware, so you need to re-calibrate key systems to ensure everything works.
First, calibrate the motion system. Run a “linear move test”: program the robot to move from the pick position to the drop position 10 times. Check for any deviations—if the robot is off by more than 1mm, you’ll need to adjust the motion offset settings.
Next, re-calibrate the vision system. For pick and place robots, the camera’s alignment is critical. Run a component recognition test: place 5 sample components (the ones you handle most often) on the conveyor, and ensure the camera identifies each one correctly, without misclassifying. If it misreads, adjust the brightness or contrast settings in the new software’s vision menu.
Then, test the EOAT grip. Run a pick-and-place cycle with a fragile component, like a glass lens. Check that the grip force is consistent—too high and it cracks the lens, too low and it drops it. The new software will often have default grip settings, but they rarely match your specific components, so tweak them manually.
Finally, run a full production test with 100–200 parts. Don’t start with 10,000 parts—start small. If even one part is misplaced, stop and troubleshoot. We tell our clients to create a “test run log” where they note any errors, so they can address them before full production.
Step 5: Document and Plan for Future Updates
Once the update is done and the robot is running smoothly, don’t just move on to the next task. Document every detail: the software version you installed, the date, any calibrations you adjusted, and any issues you fixed. This log will save you hours of time when it’s time for the next update.
As a pick and place robot supplier, we recommend scheduling software updates every 6–12 months, or after a major change to your production line (like adding a new component type). Outdated software doesn’t just cause downtime—it can lead to missed productivity gains. For example, a client we worked with in 2022 waited 2 years to update their software, and when they finally did, they saw a 12% increase in daily output, with no new hardware investment.
We also offer proactive update reminders for our clients, so you never miss a critical update. If you’re not a client, mark your calendar for updates, and make sure your team knows to test backups before any installation.
Now, let’s address a common question we get: “Can I update the software myself, or do I need to hire a technician?” While it’s possible for experienced maintenance teams to do the update, we always recommend having a qualified technician on-site for the first update on a new robot, or if you’re upgrading to a major version (like from v2.8 to v3.0). Major updates can include new features like AI-powered component detection, which requires specialized knowledge to set up correctly. Smaller updates (v2.7.1 to v2.7.2) are often safe to do in-house, as long as you follow the steps above.
Another common mistake: ignoring “minor” updates. Software releases label some updates as “minor” because they don’t add new features, but they fix critical bugs—like a glitch that causes the robot to misplace parts after 1,000 cycles, or a security flaw that could let hackers access your production line’s data. We saw a small electronics factory get hit with a ransomware attack last year because their pick and place robot’s software had an unpatched security vulnerability. Minor updates aren’t just about fixing bugs—they’re about keeping your operations secure.
If you’re ready to update your pick and place robot’s software, or if you have questions about compatibility, calibration, or upcoming releases, our team is here to help. We work with factories of all sizes, from small food packaging lines to large automotive assembly plants, and we tailor every update to your specific robot and production needs. Don’t let outdated software hold back your efficiency—reach out to our team to discuss a software update that fits your operations.
Pick and Place Robot References
- International Organization for Standardization (ISO). Industrial Robot Safety Requirements for Pick and Place Operations, 2021.
- Robotic Industries Association (RIA). Best Practices for Industrial Robot Software Maintenance, 2022.
- The Manufacturing Institute. Impact of Outdated Automation Software on Production Efficiency, 2023.
- Pick and Place Robot Suppliers Association. Field Guide to Robot Software Updates, 2022.
Robotic Technology (GD) Co., Ltd.
Robotic Technology (GD) Co., Ltd. is one of the most experienced pick and place robot manufacturers and suppliers in China, also supports custom service and one year warranty. Please feel free to wholesale CE approved pick and place robot for sale here from our factory. Contact us for quotation.
Address: Room 102, No. 30,Hengfeng 2nd Road,Daguo, Changping Town, Dongguan City,Guangdong,China
E-mail: admin@iroboticplus.com
WebSite: https://www.rb-tic.com/
